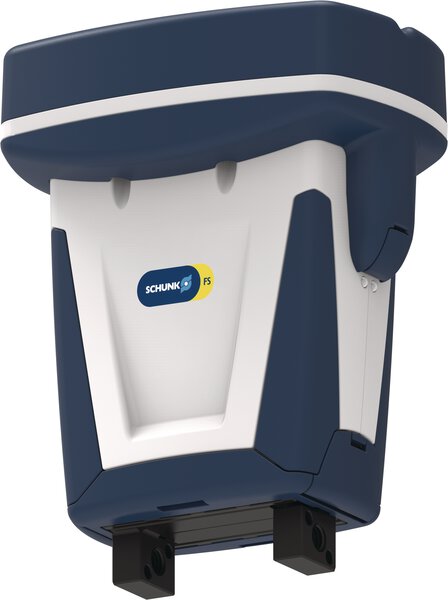
SCHUNK Co-act EGP-C 64-N-N-URID servo-electric parallel gripper for collaborative applications. Compatible with Universal Robots UR3/5/10/16 e-Series only. Force, stroke and recommended-workpiece figures retain manufacturer qualifiers.
Standard specifications
| Product model | Co-act EGP-C 64-N-N-URID |
|---|---|
| Gripper type | parallel |
| Rated payload | Recommended workpiece mass: 1.15 kg (manufacturer-recommended value; not rated robot payload) |
| Grip force | Minimum 65 N; maximum 230 N total across both jaws; per jaw: 32.5–115 N |
| Stroke / opening | 10 mm per jaw |
| Finger length | Maximum permitted finger length: 80 mm |
| Repeatability | Gripping repeat accuracy: 0.02 mm |
| Supply voltage | 24 V |
| Ingress protection | IP30 |
| Dimensions | 125.5 × 86.4 × 149.2 mm (X × Y × Z) |
| Weight | 1.11 kg |
| Operating temperature | 5 to 55 °C |
Additional manufacturer specifications
| Technical extension parameters | Compatible robot: Universal Robots UR3/5/10/16, e-Series only; standard robot flange; integrated inductive sensors in two directions; opening time 0.49 s; closing time 0.49 s; maximum permitted finger mass 0.24 kg per finger; M8 connector; 90 mm cable; nominal current 0.15 A; maximum total current 2.0 A; integrated control electronics; two digital inputs and two digital outputs; maximum static moments Mx 3.5 Nm, My 6 Nm, Mz 9 Nm; maximum axial force Fz 250 N; rack-and-pinion operating principle; servo-electric actuation via brushless DC motor; glass-fiber-reinforced polyamide housing; steel base jaws. Opening/closing times exclude application-specific fingers and PLC reaction time. Recommended workpiece mass is not a rated robot payload. |
|---|
Official English manufacturer source: https://schunk.com/us/en/gripping-systems/parallel-gripper/co-act-egp-c/co-act-egp-c-64-n-n-urid/p/000000000001436401