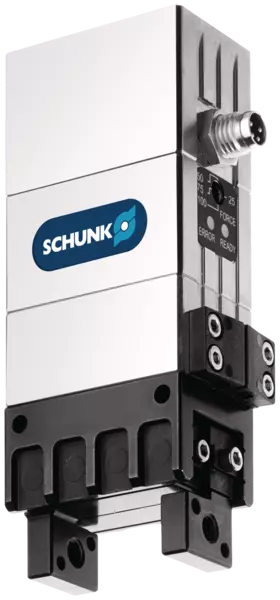
SCHUNK EGP 40-N-N-B servo-electric parallel gripper for small components. Manufacturer-published performance, dimensional, electrical and operating data are presented with their original qualifiers.
Standard specifications
| Product model | EGP 40-N-N-B |
|---|---|
| Gripper type | parallel |
| Rated payload | Recommended workpiece mass: 0.7 kg (manufacturer-recommended value; not a rated robot payload) |
| Grip force | Minimum 35 N; maximum 140 N (manufacturer defines gripping force as the arithmetic sum of force on both jaws) |
| Stroke / opening | 6 mm per jaw |
| Finger length | Maximum permitted finger length: 50 mm |
| Repeatability | Gripping repeat accuracy: 0.02 mm |
| Supply voltage | 24 V |
| Ingress protection | IP30 |
| Dimensions | 40.0 × 26.0 × 88.4 mm (X × Y × Z) |
| Weight | 0.32 kg |
| Operating temperature | 5 to 55 °C |
Additional manufacturer specifications
| Technical extension parameters | Opening time 0.2 s; closing time 0.2 s (base jaws only; excludes application-specific fingers and PLC reaction time); maximum total current 2.0 A; nominal current 0.2 A; recommended workpiece mass 0.7 kg; maximum permitted finger length 50 mm; maximum permitted finger mass 0.08 kg per finger; cleanroom class ISO 14644-1 Class 5 (1999); communication interface digital I/O with two digital inputs; noise emission <70 dB(A); rack-and-pinion operating principle; servo-electric actuation via brushless DC servomotor; coated aluminum-alloy housing and steel base jaws; maximum static moments per jaw Mx 1.5 Nm, My 2.0 Nm, Mz 4.0 Nm; maximum axial force Fz 170 N; 24-month warranty. Manufacturer defines gripping force as the arithmetic sum of forces on the two jaws; workpiece mass is a recommended value, not robot payload. |
|---|
Image note: SCHUNK identifies the official product-page image as an illustration similar to the selected variant.
Official English manufacturer source: https://schunk.com/us/en/gripping-systems/parallel-gripper/egp/egp-40-n-n-b/p/000000000000310940